Projects.
Structures, vehicles, and autonomous systems.
01
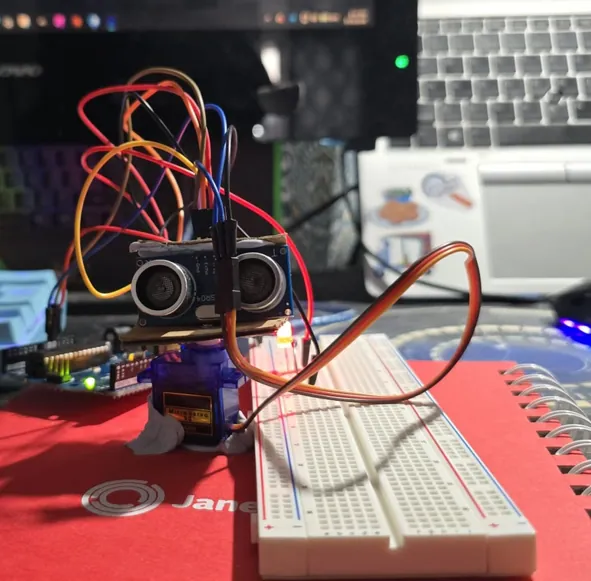
Autonomous Radar Scanner
A 180° ultrasonic radar built around an Arduino UNO: an HC-SR04 rangefinder on a servo sweeps the field of view while a Processing app renders detections in real time. All sweep and detection logic written from scratch in C++.
Outcome
Real-time object mapping across the full 180° sweep with a live radar display.
02
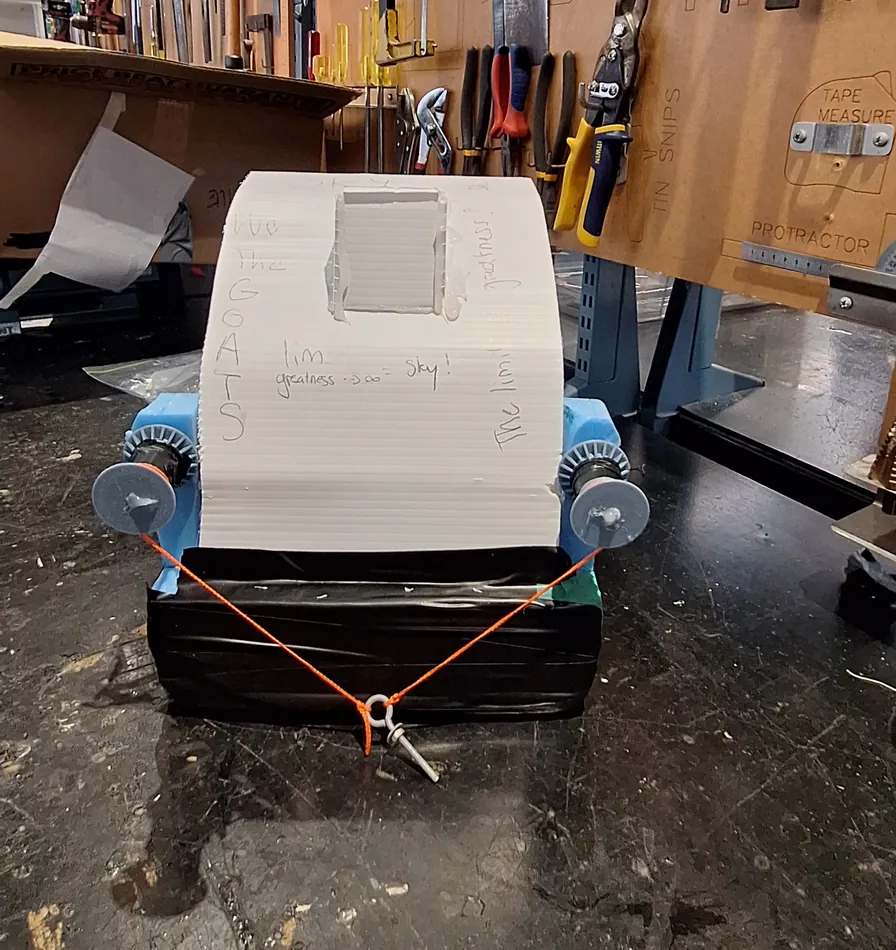
Flood-Resistant Station-Keeping House
A model house that holds position in rising floodwater. I led a seven-person team and owned the electronics and firmware: an Arduino UNO R3 reading an MPU-6050, driving DC motors through an L298N H-bridge on an XPS foam hull.
Outcome
Held position under simulated flood conditions, delivered under the $170 AUD budget.
03
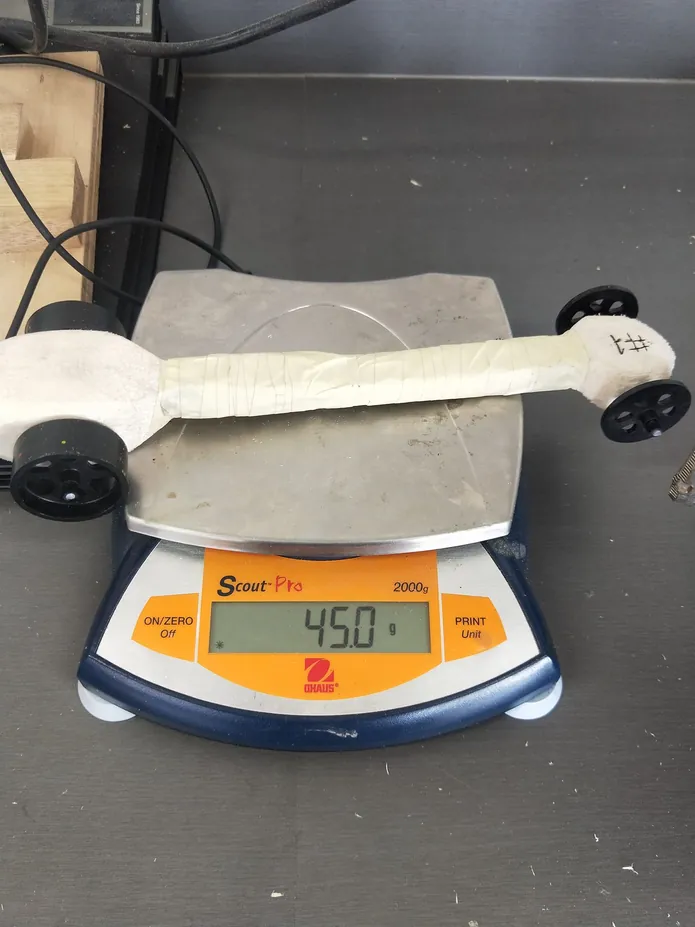
CO2 Dragster
A 45 g CO2-powered dragster modelled in Fusion 360 and machined from balsa, shaped to minimise frontal area and drag within competition rules.
Outcome
0.49 s over the 1 m track, top 5 in the year group.
04
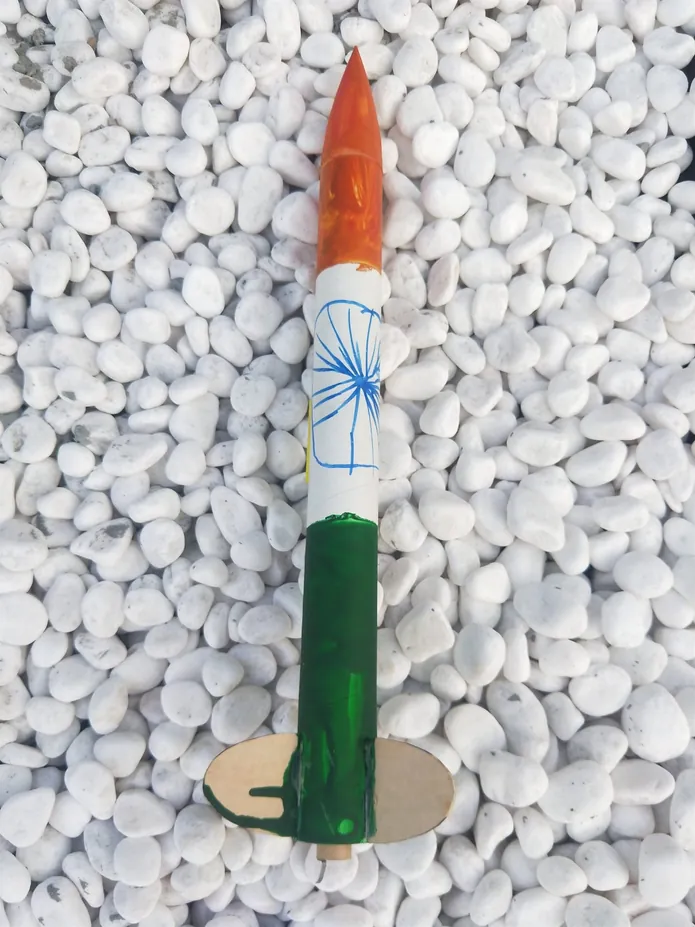
Model Rocket
Designed and simulated in OpenRocket to verify the stability margin before construction, then built, balanced, and launched on a B6-4 motor.
Outcome
97 m apogee, stable flight, clean parachute recovery.
05
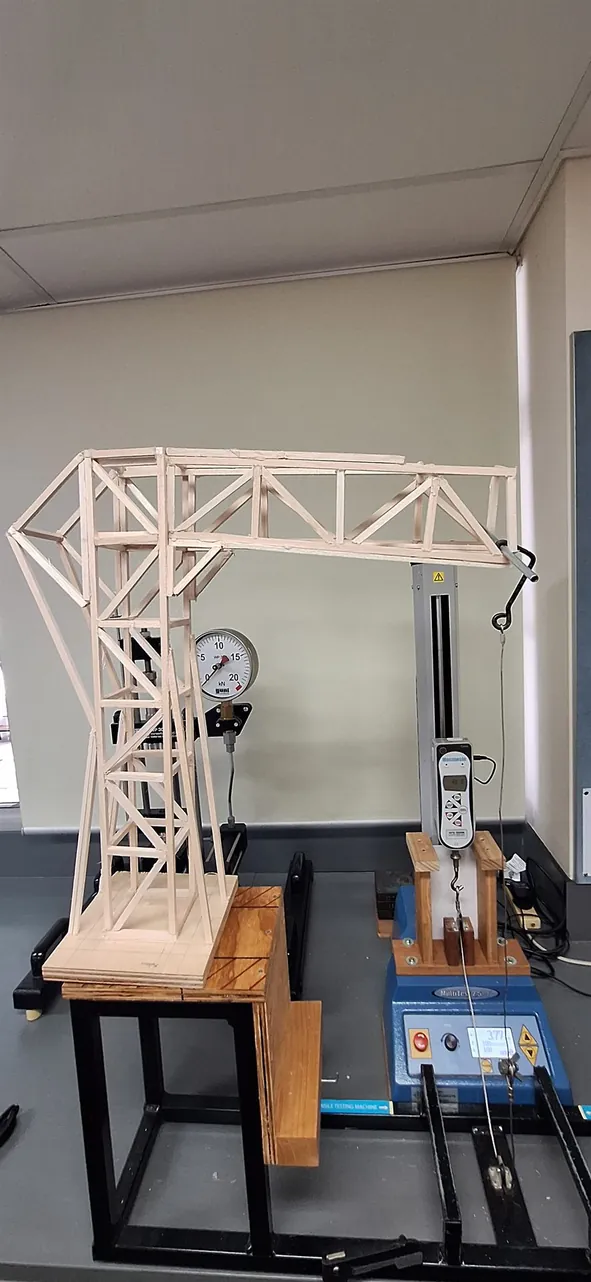
Balsa Truss Tower
A balsa truss tower built for a structural efficiency competition. Geometry chosen to maximise load-to-weight ratio with predictable load paths; joints pinned and glued with weight tracked through the build.
Outcome
Failed exactly at the designed weak point under class load testing.
06
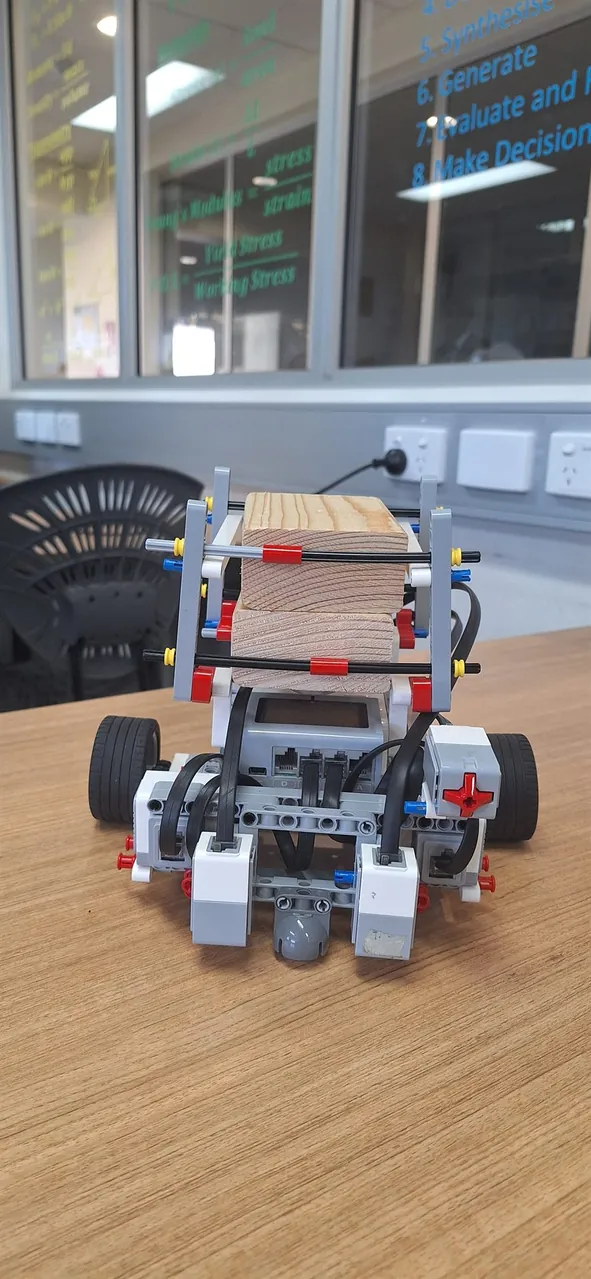
Autonomous Warehouse Rover
A LEGO Mindstorms EV3 rover programmed to clear a warehouse-style obstacle course with no human input: ultrasonic sensor for obstacle detection, colour sensor for line following.
Outcome
Completed the full course autonomously.