Autonomous Radar Scanner.
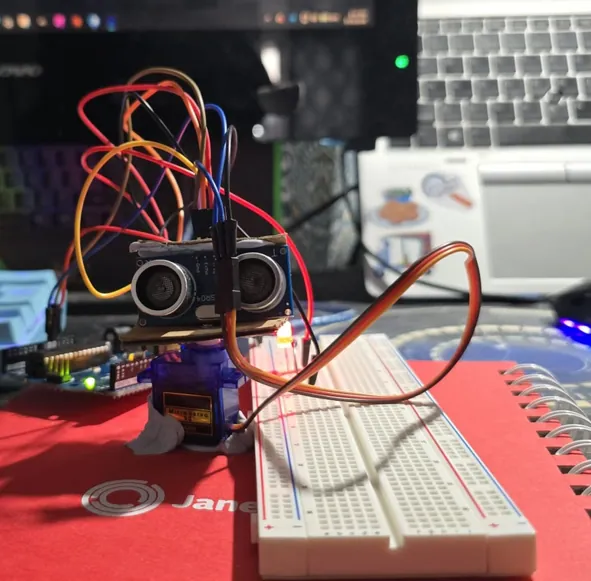
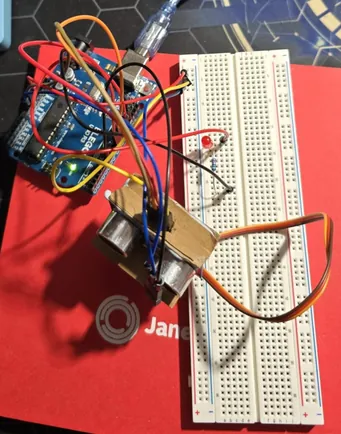
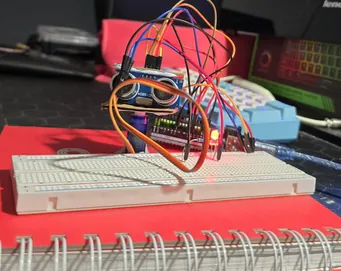
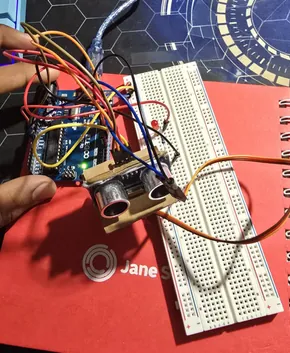
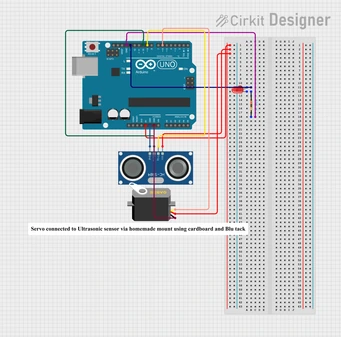
A 180° ultrasonic radar built around an Arduino UNO: an HC-SR04 rangefinder on a servo sweeps the field of view while a Processing app renders detections in real time. All sweep and detection logic written from scratch in C++.
→ Real-time object mapping across the full 180° sweep with a live radar display.
Challenge
Debugging embedded hardware with no prior experience. Staying methodical when nothing worked and every path seemed like a dead end.
What I Did
Taught myself C++ from scratch. Wrote all sweep and detection logic. Resolved a critical servo mounting failure. Built a live radar visualisation UI in Processing.
Result
Fully functioning radar scanner with live UI. Real-time object mapping at 180°. Code is public on GitHub.
Get in touch.
I'm after internships and project work in autonomous systems and aerospace.